 Contact us
RN AI kitBeginner
Line follower robot
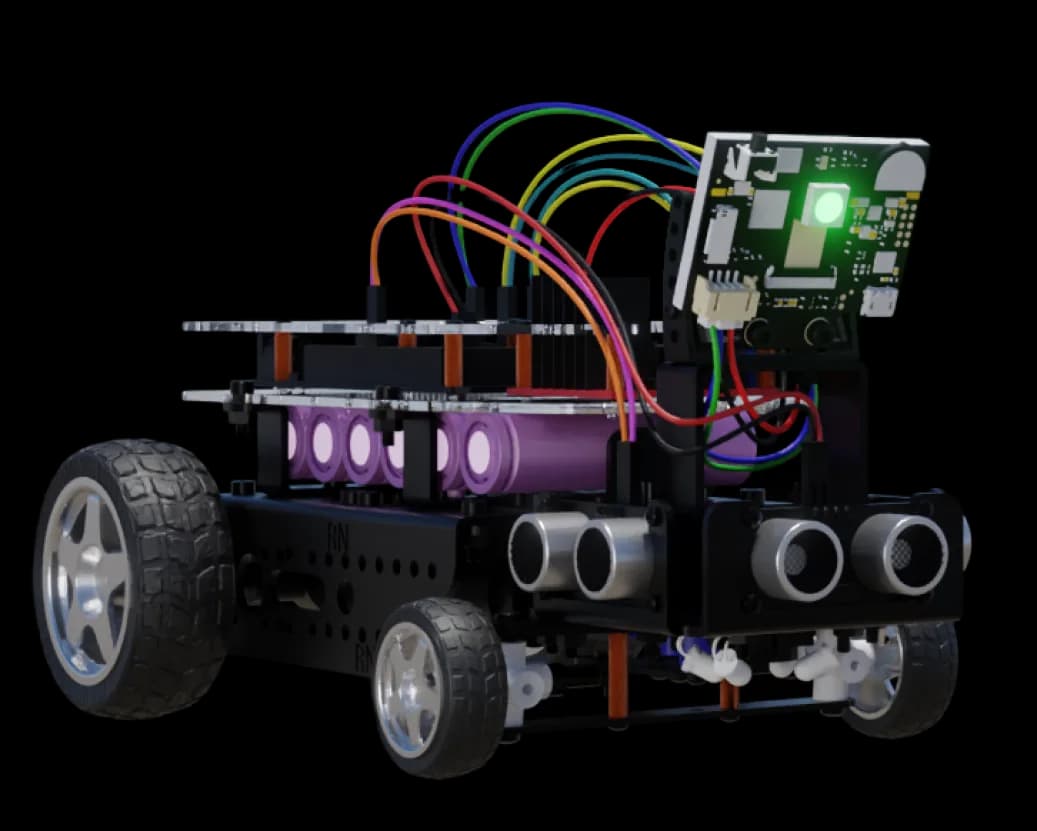
Objective: Build a robot that follows a black line using infrared sensors.
Steps
- 1
Assembly
Mount the chassis, wheels and sensors.
- 2
Wiring
Connect the sensors to the controller as shown.
- 3
Programming
Upload the code and test on the track.
Code
# placeholder
while True:
    left, right = read_sensors()
    steer(left - right)